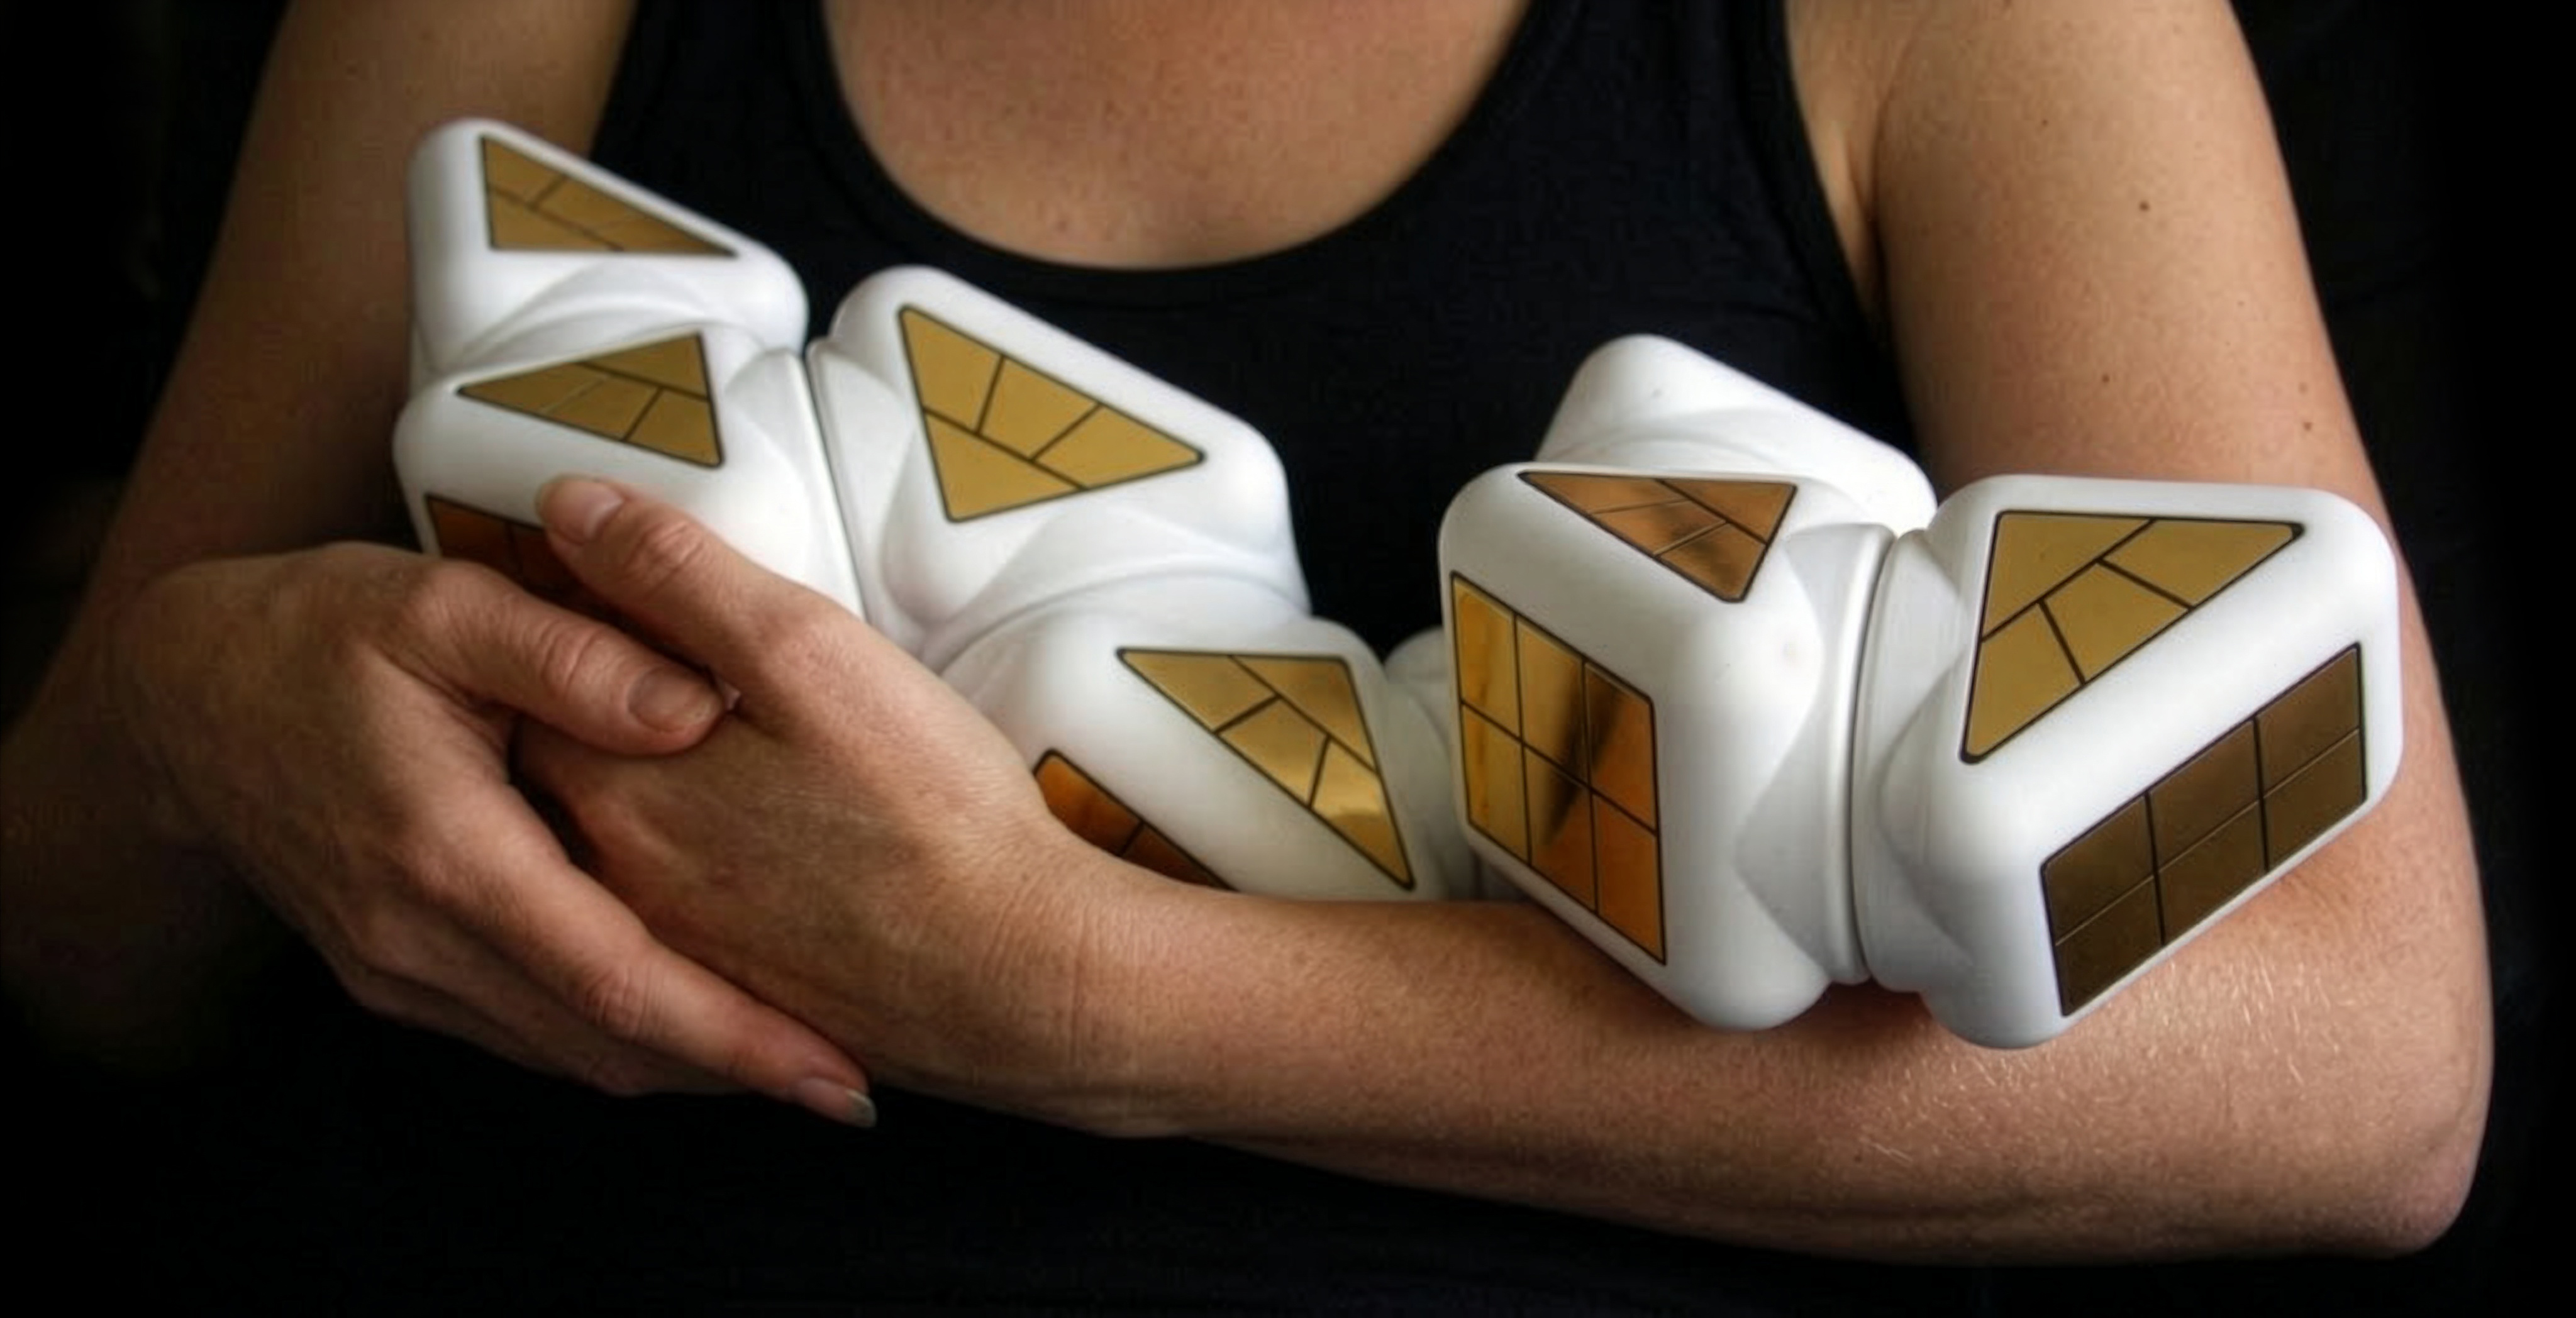
PET’s body is optimized for being lifted, cradled, and repositioned in human arms. With smooth surfaces, each module is endowed with varied sensors, and joined by compliant, proprioceptive motors. Like pixels, PET’s modularity increases the resolution of sensing and movement.
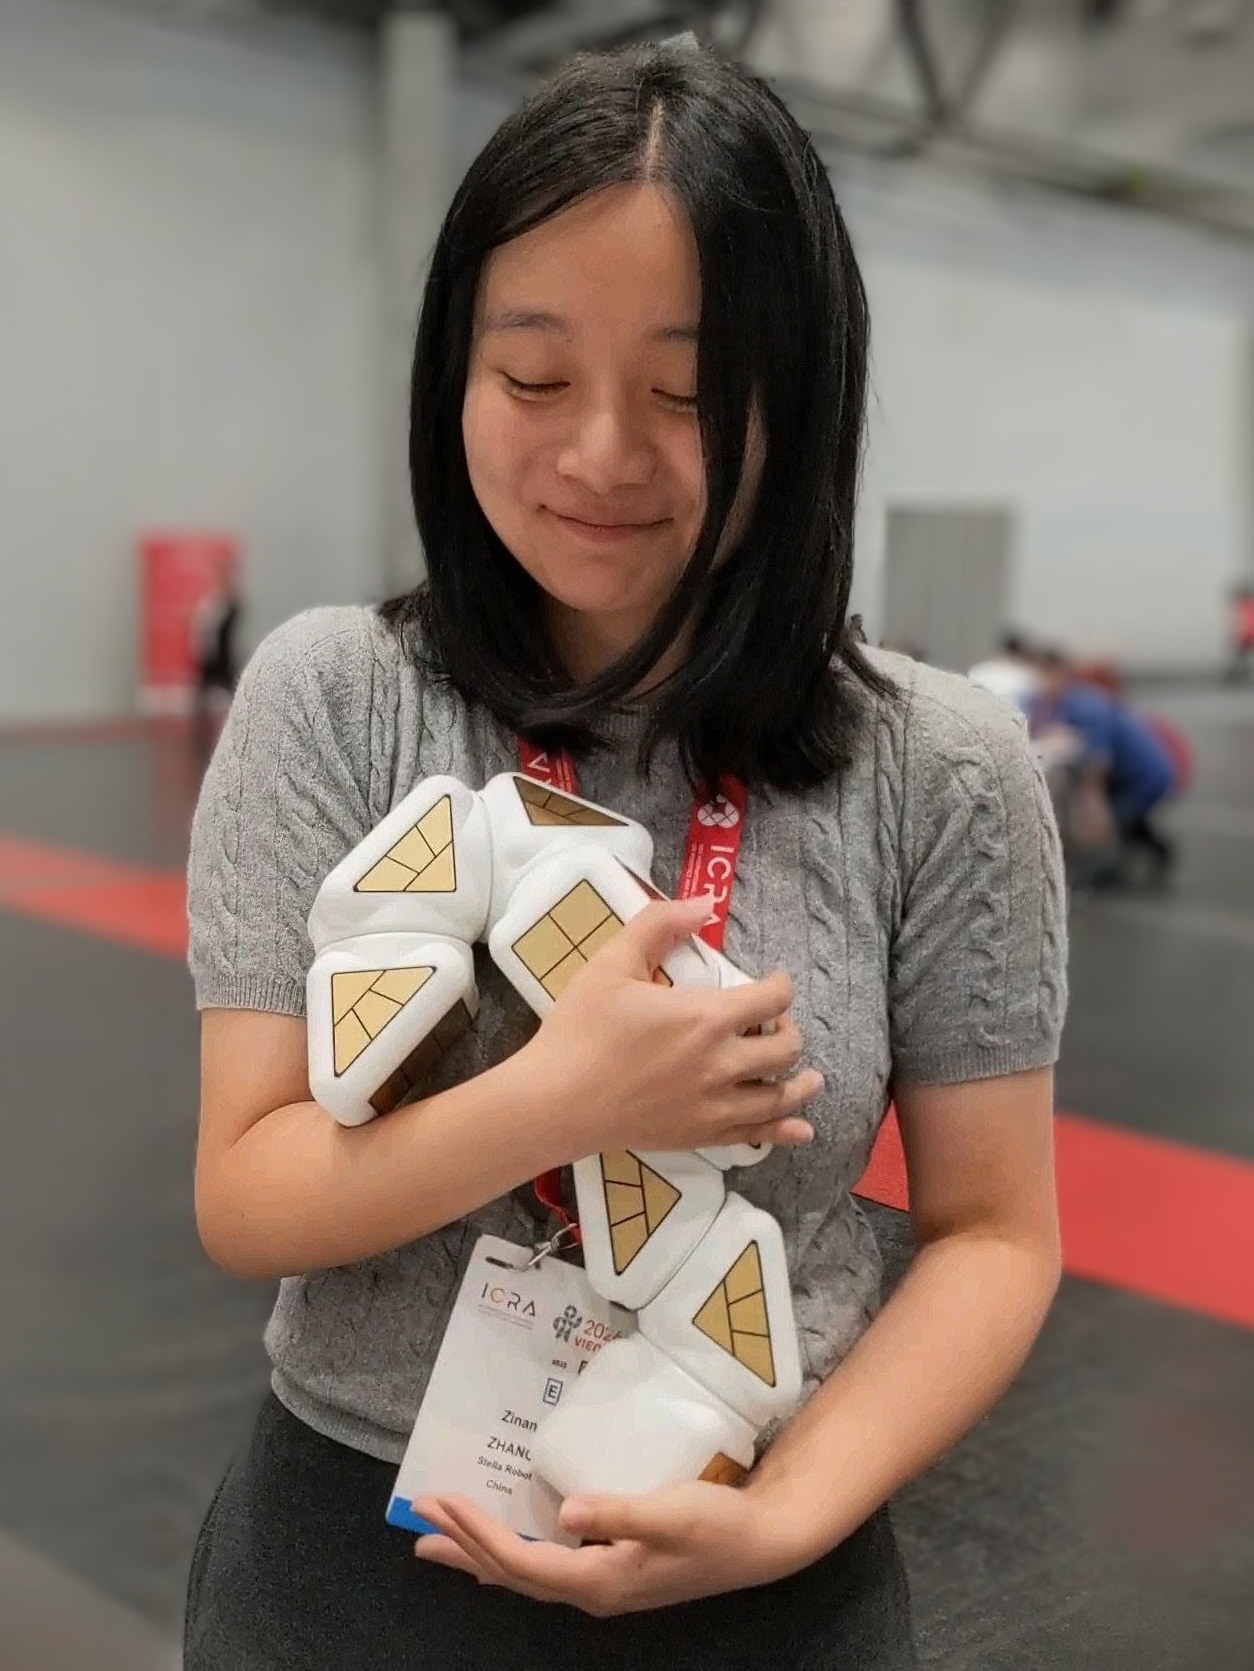
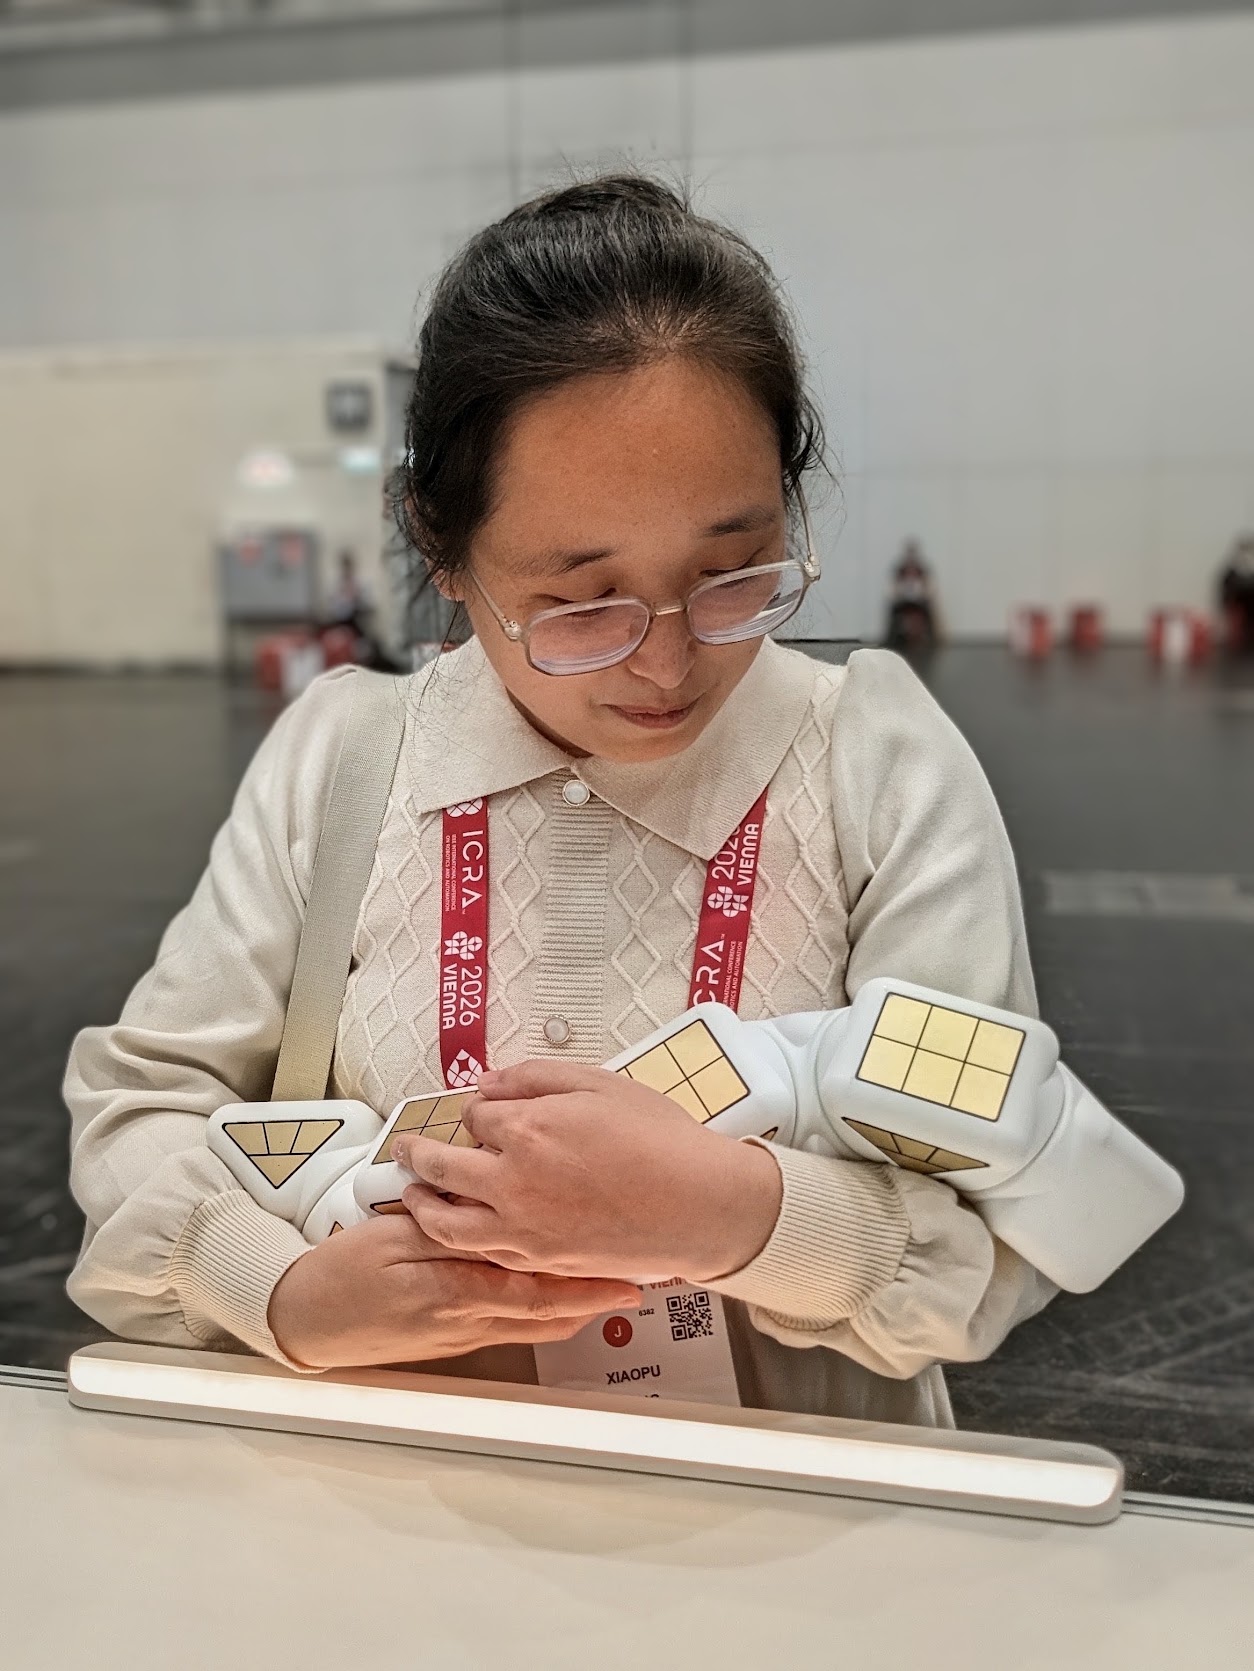
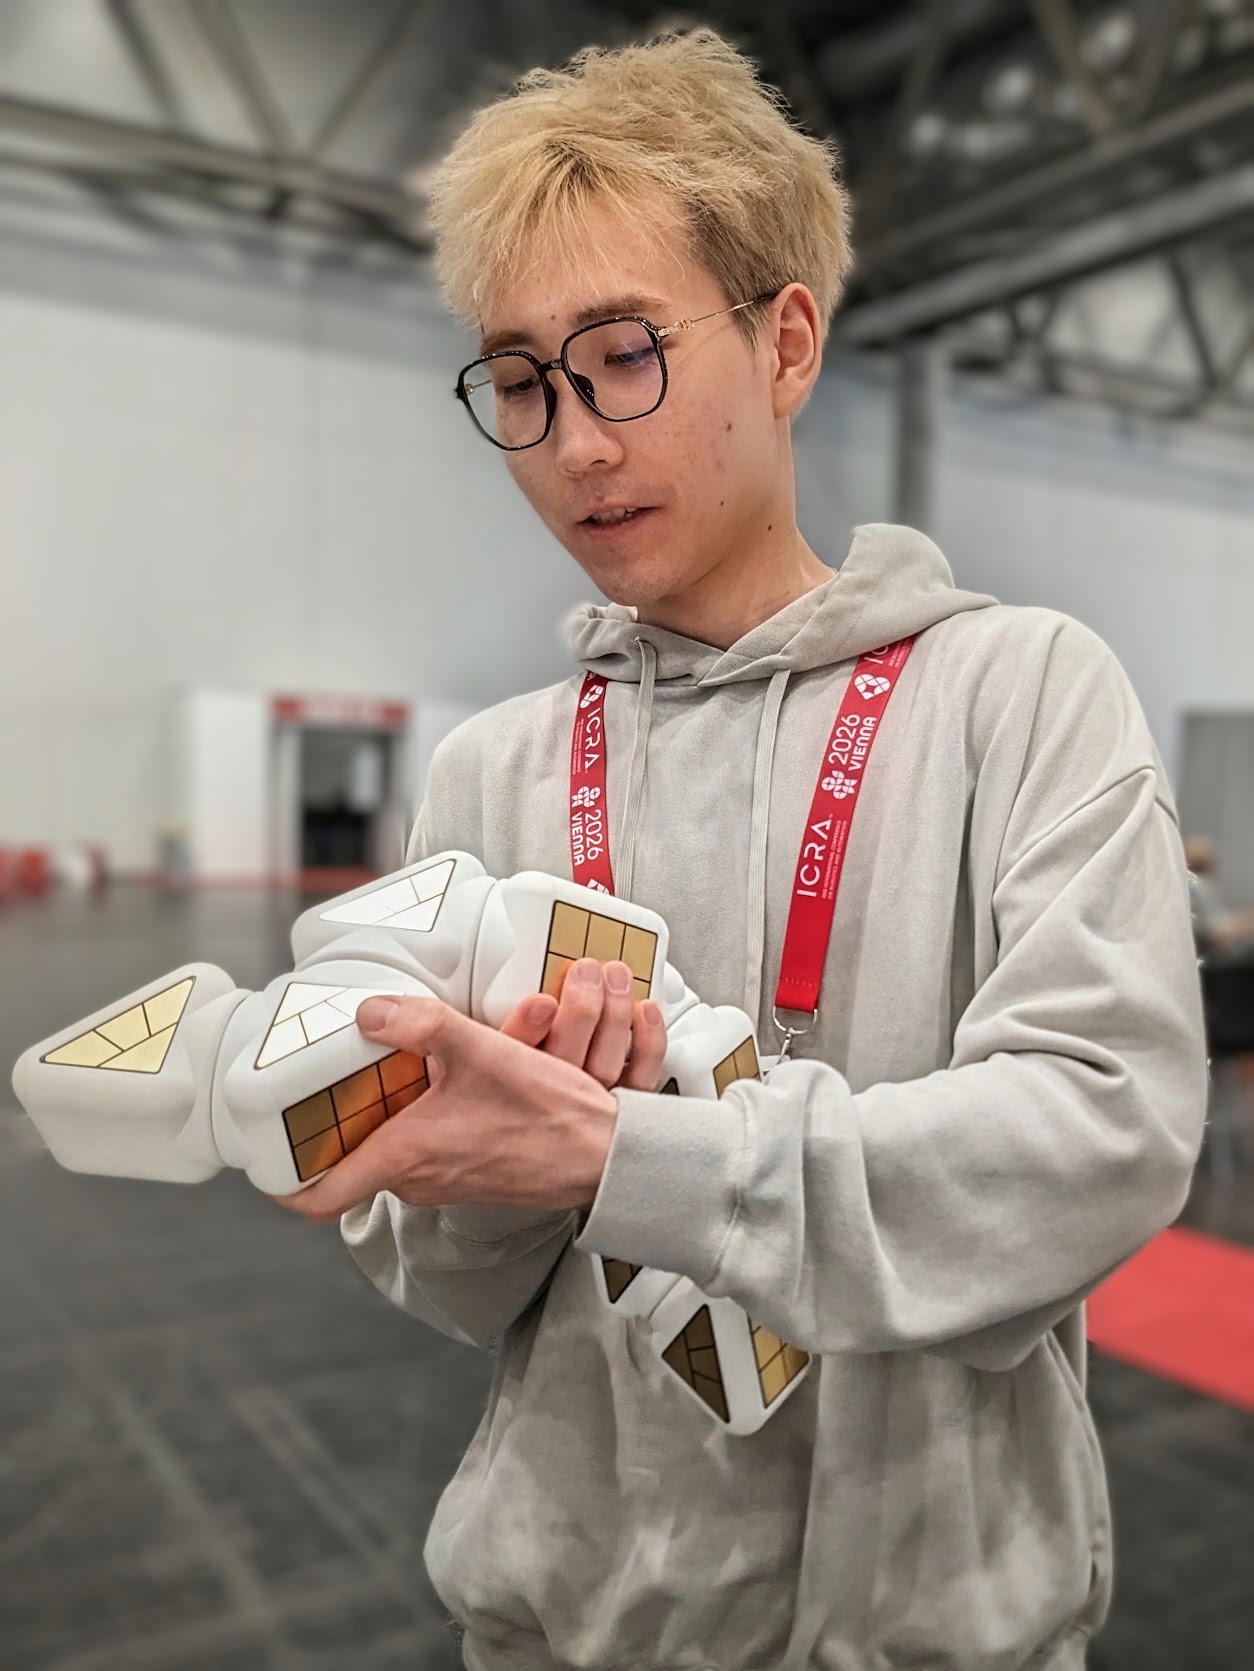
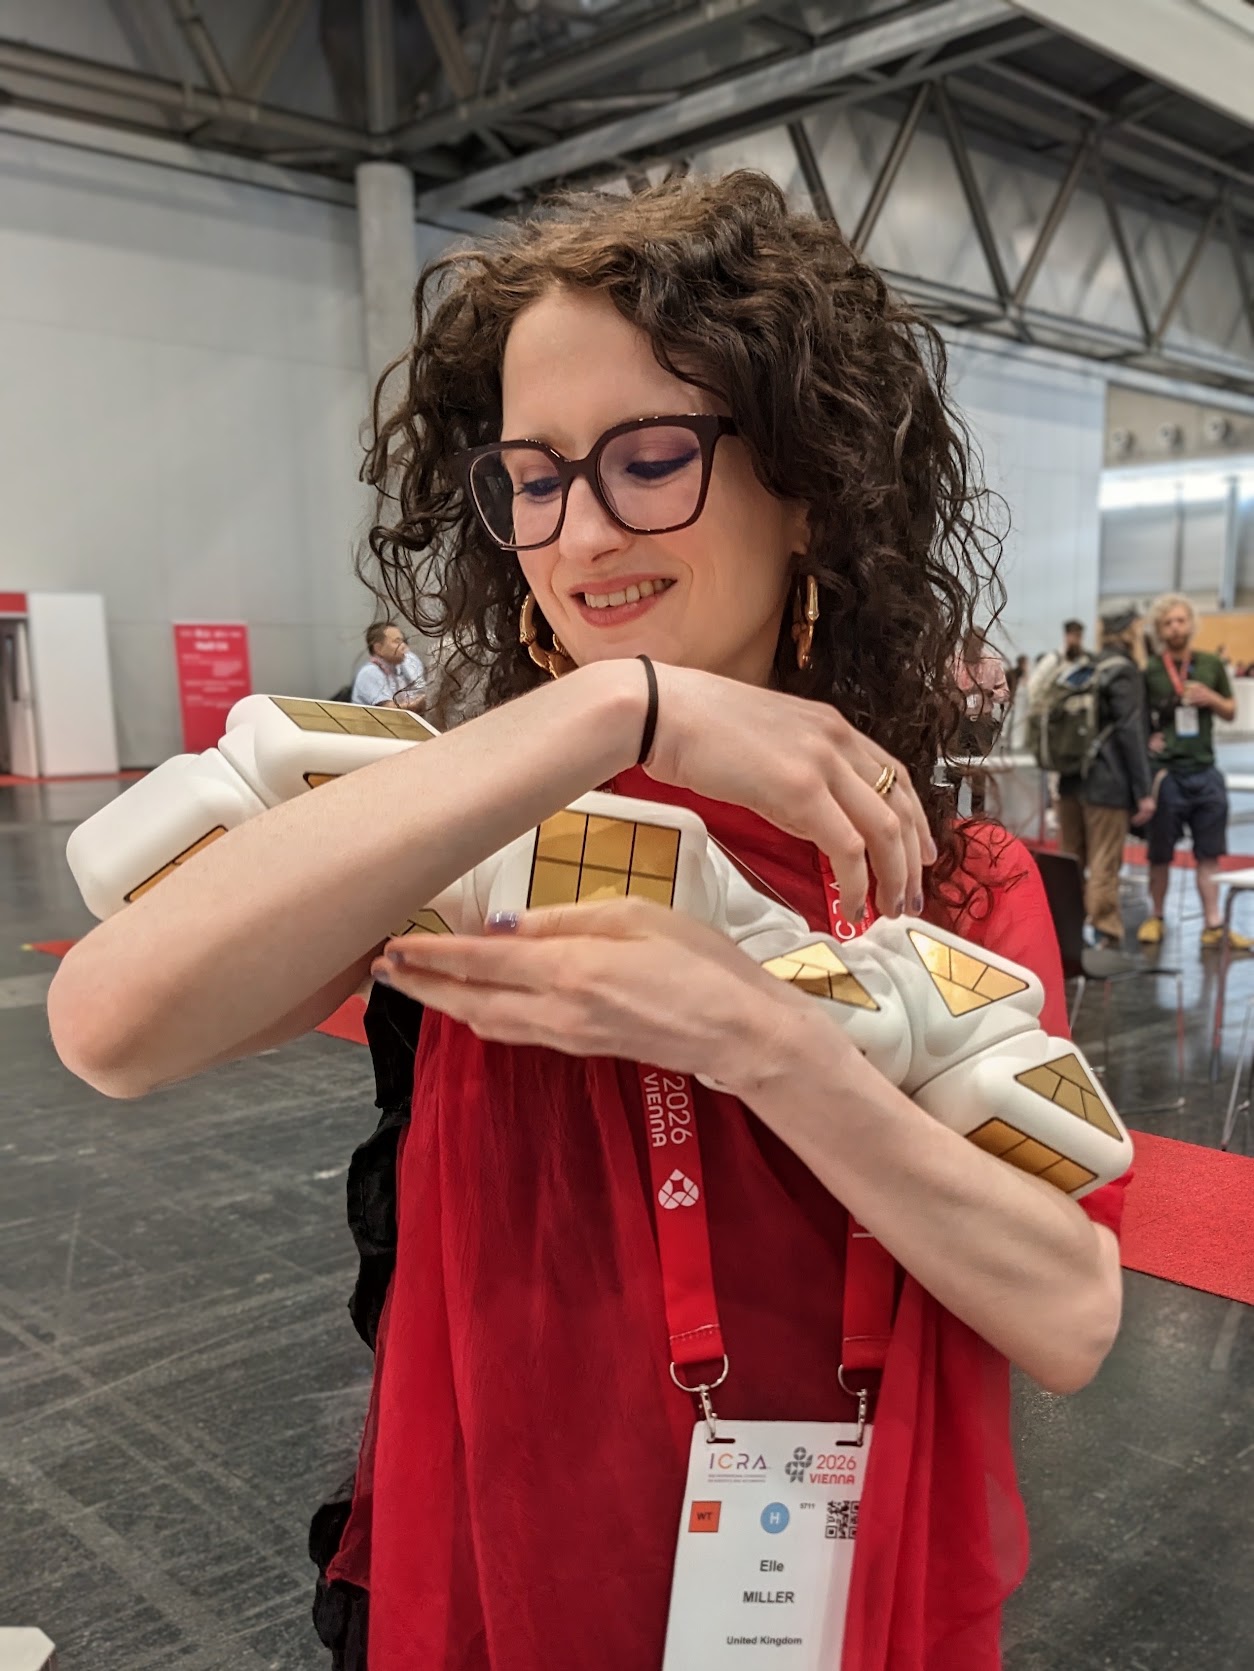
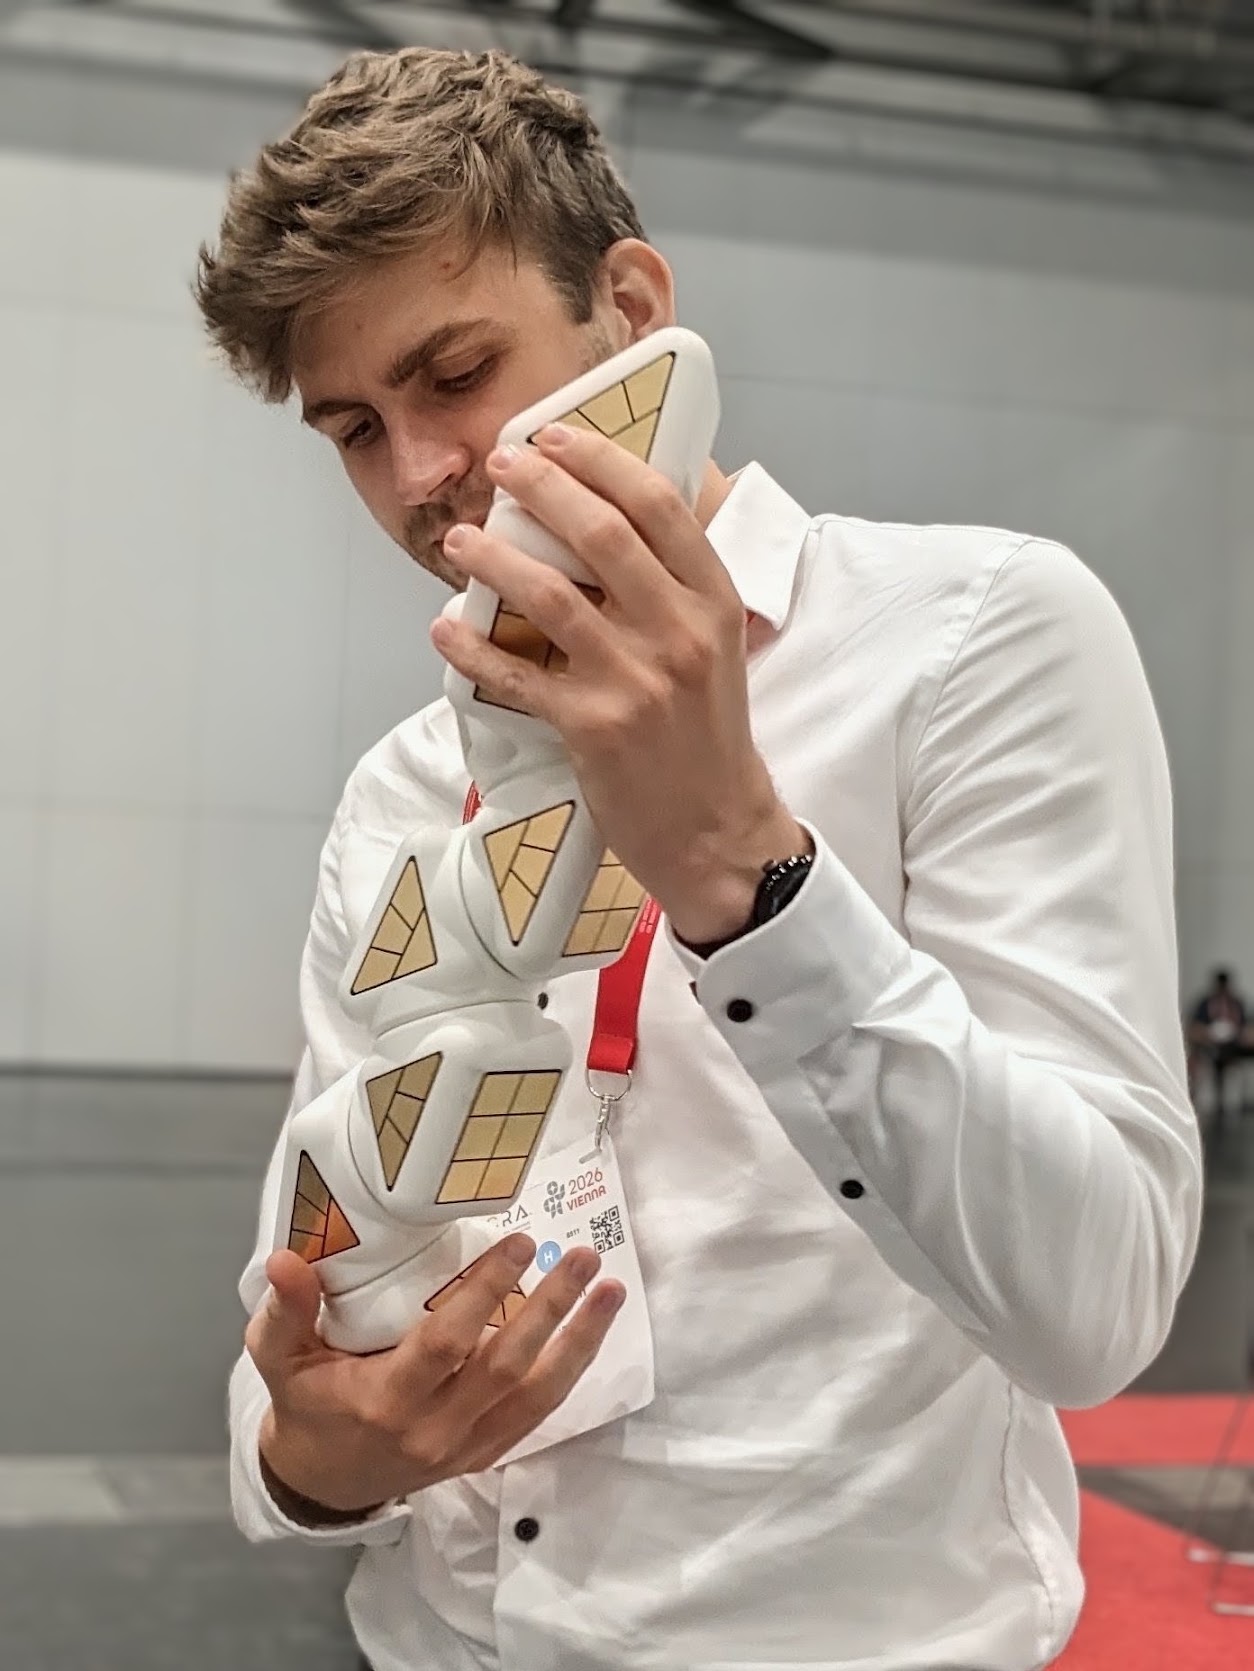
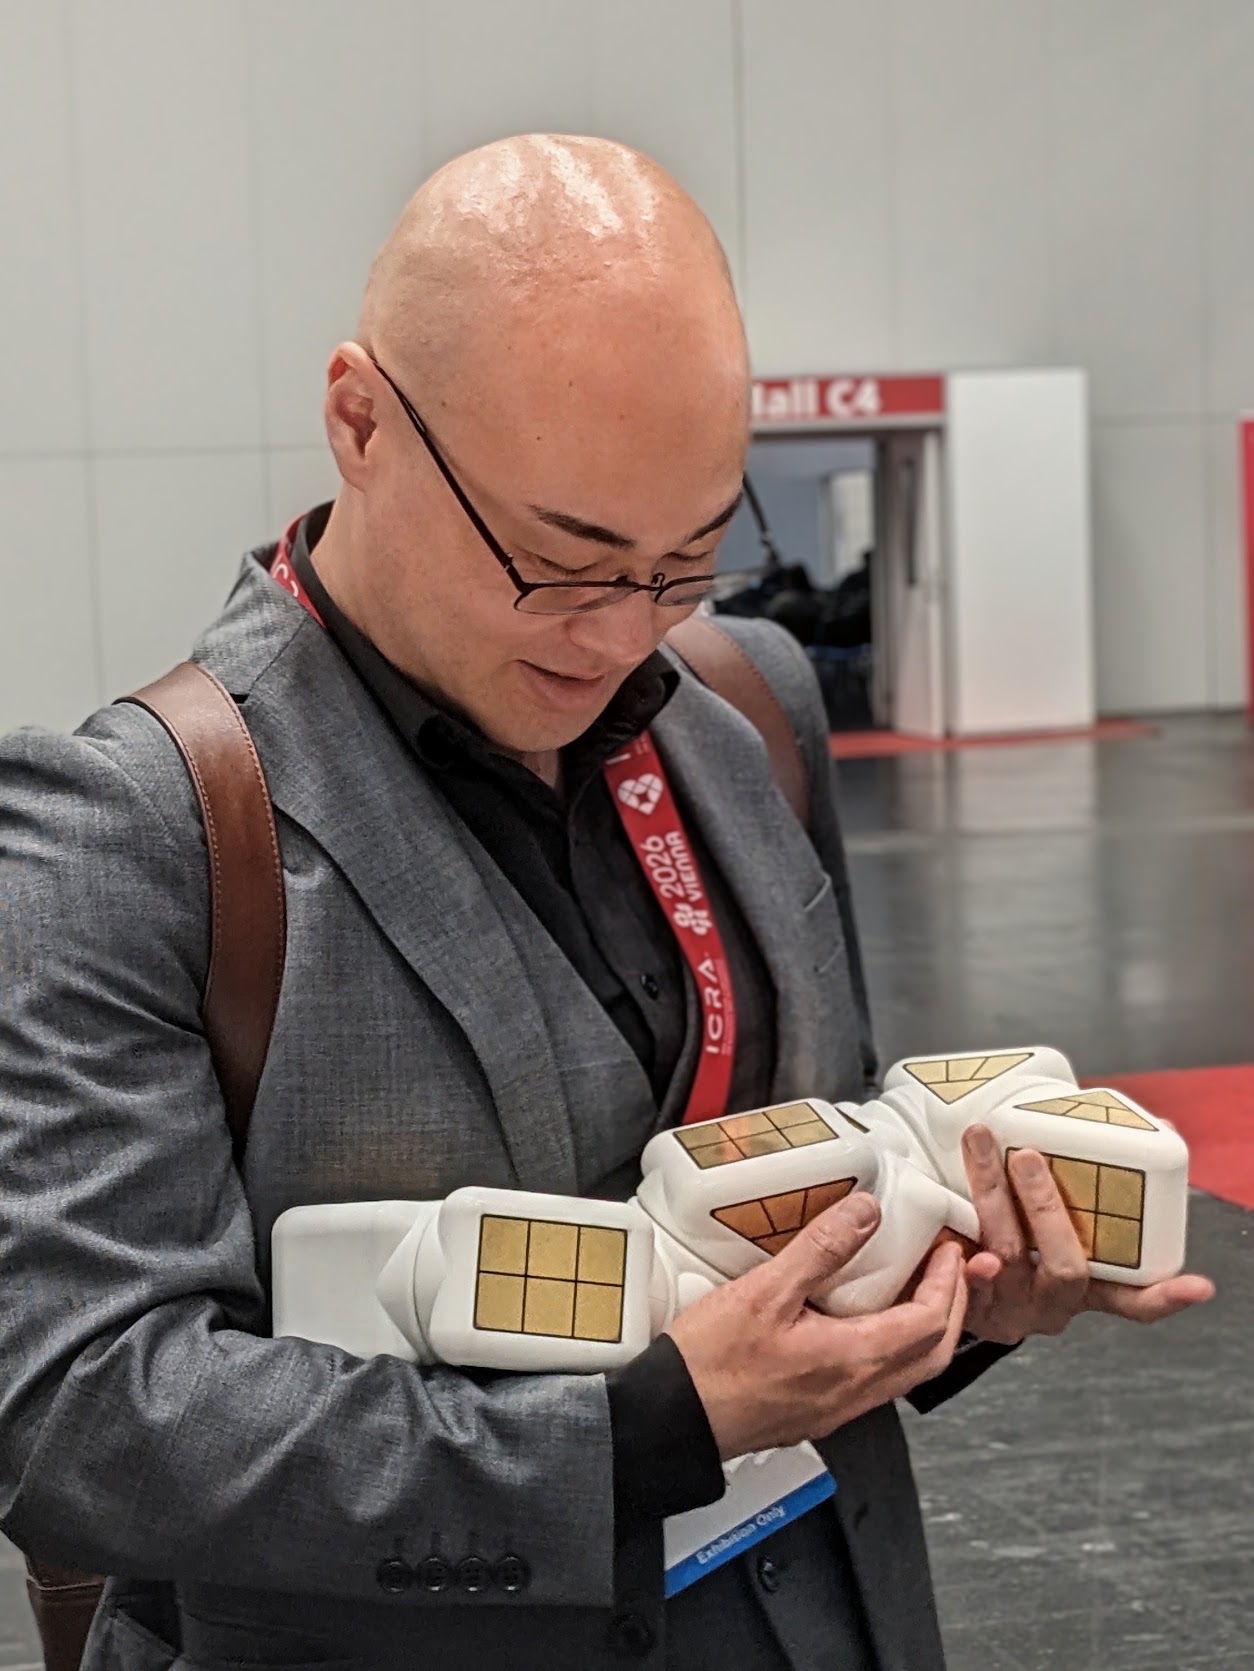
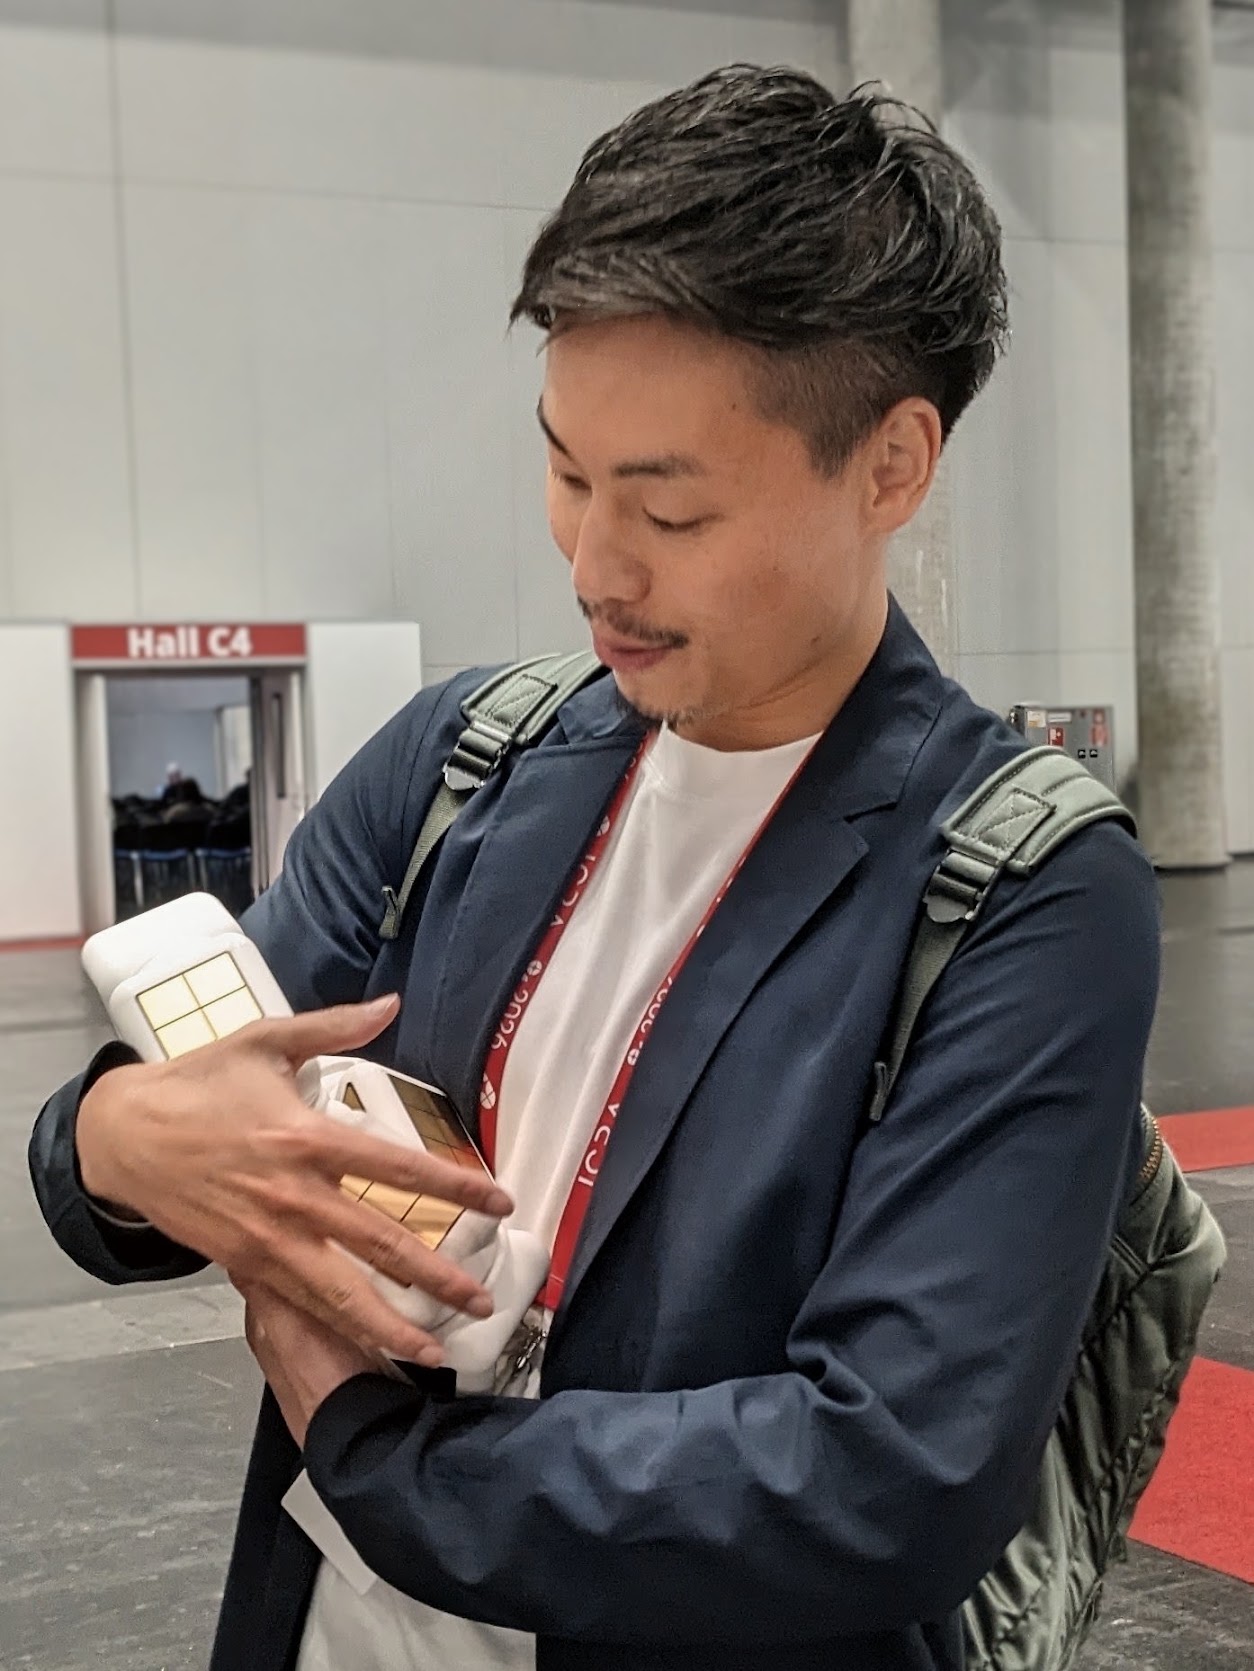
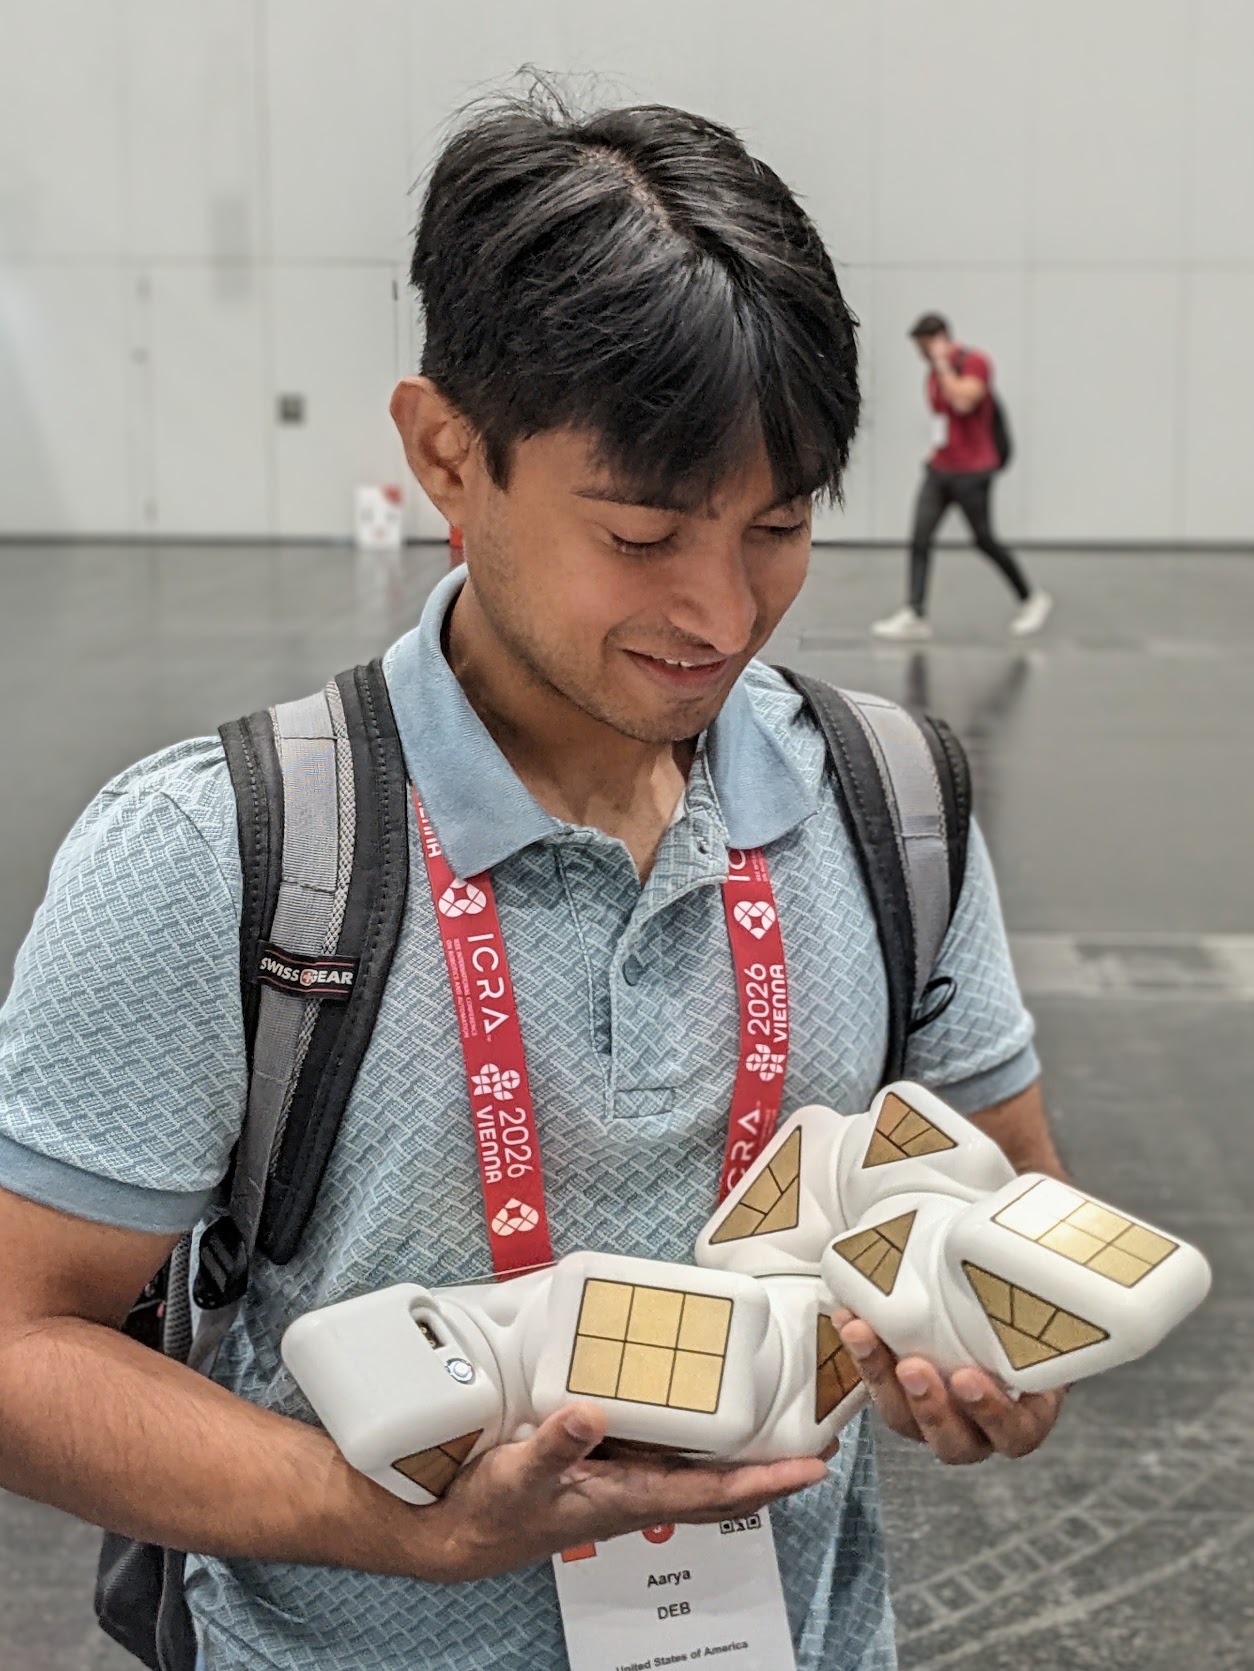
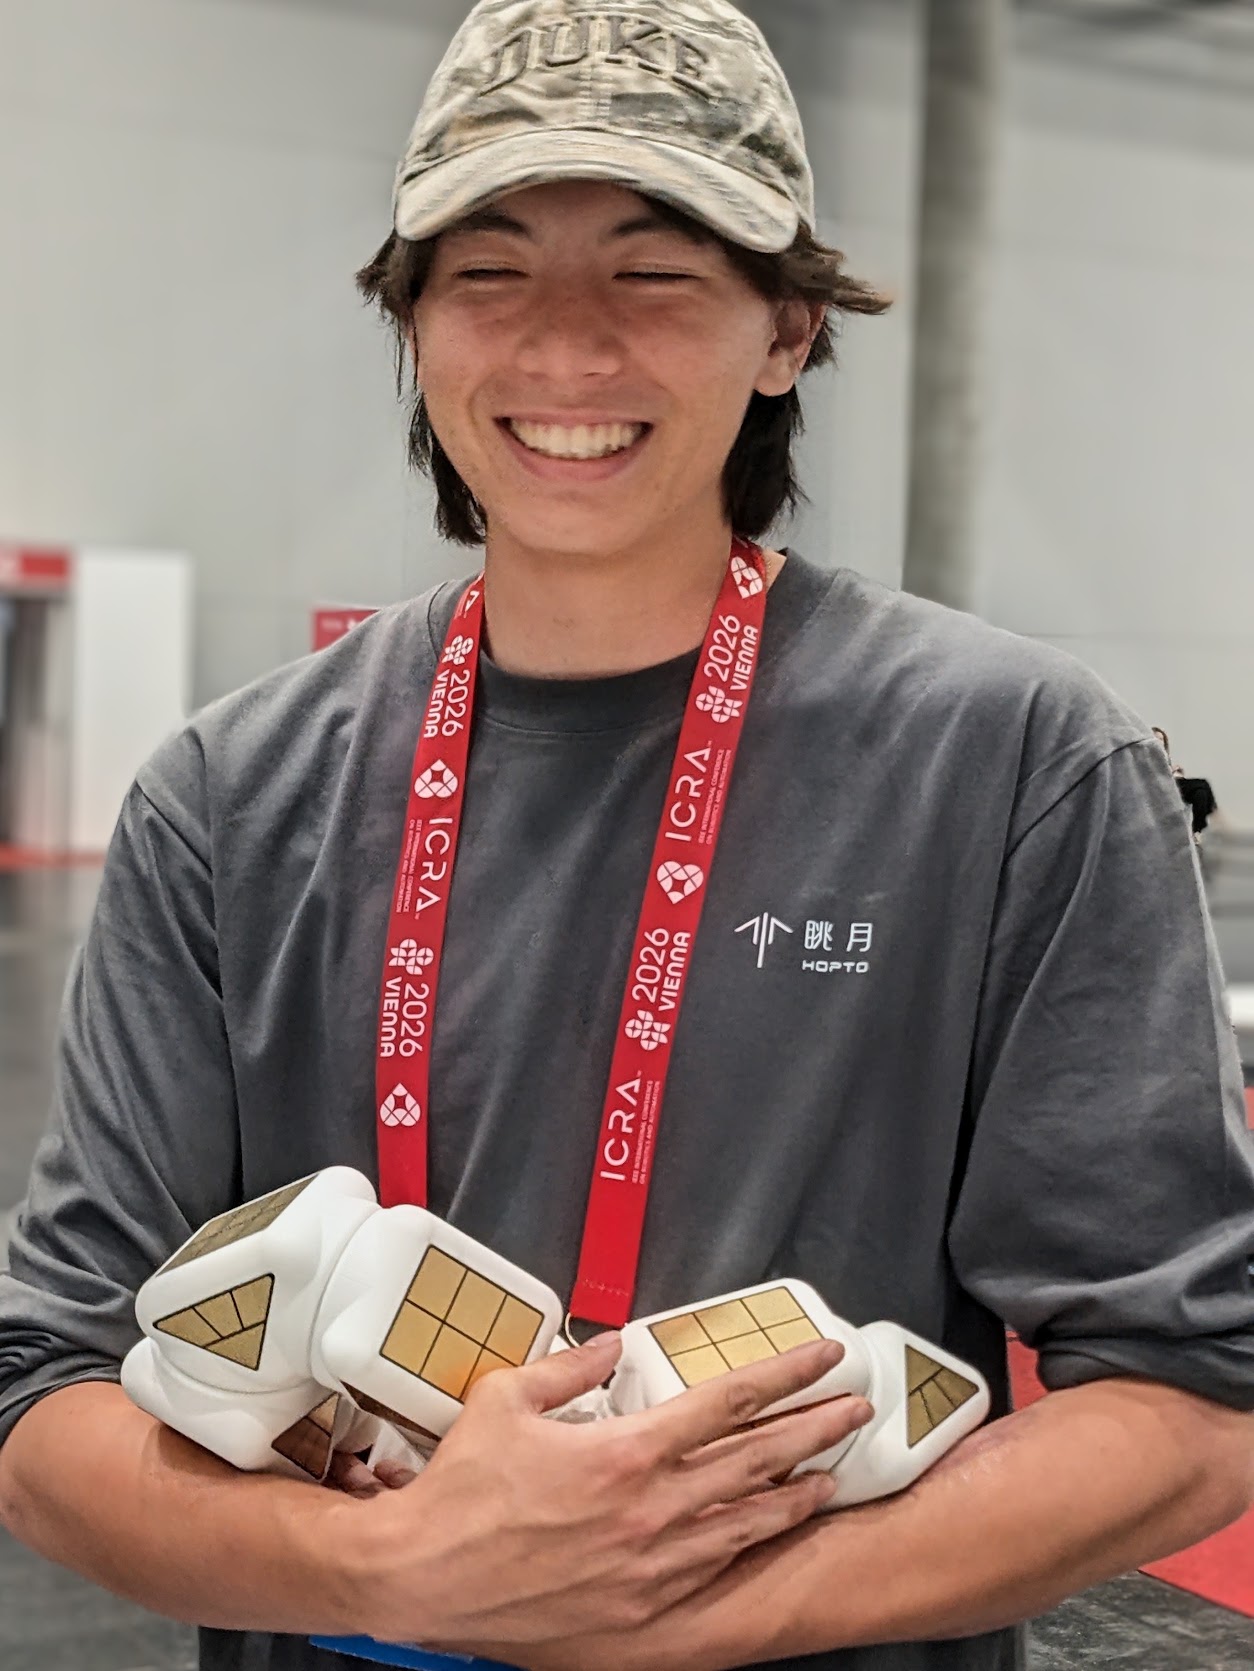
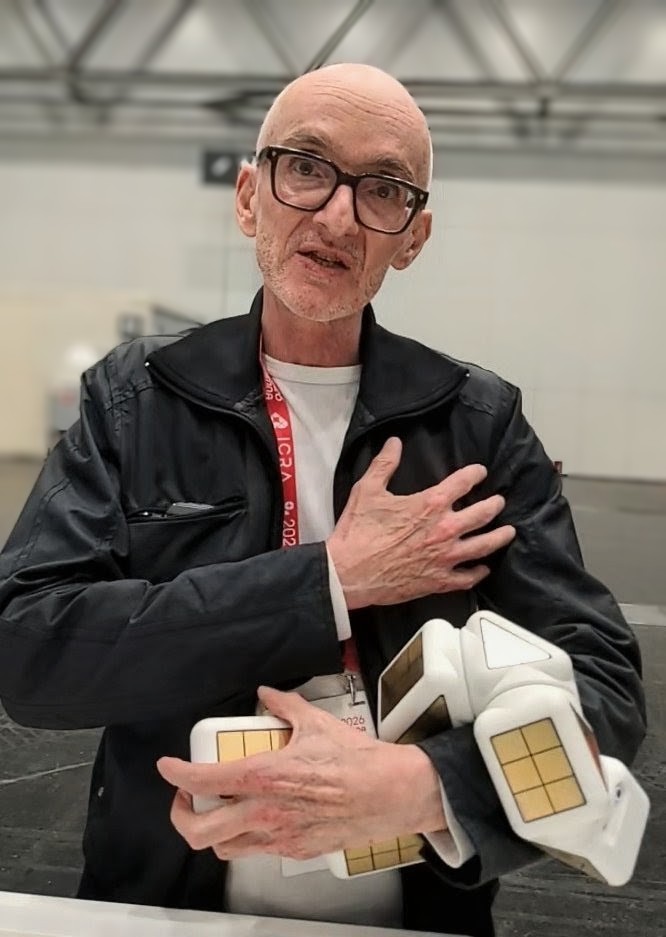
PET at ICRA
PET's movement emerges from ongoing interaction. Sensor signals are processed in real time, categorized into gestures, encoded into valenced language (e.g. stroke vs. poke), processed by an LLM that enacts movements reflecting how it feels about the way it is being touched. The result is an embodied agent whose expressiveness emerges from how it feels rather than anthropomorphic imitation.
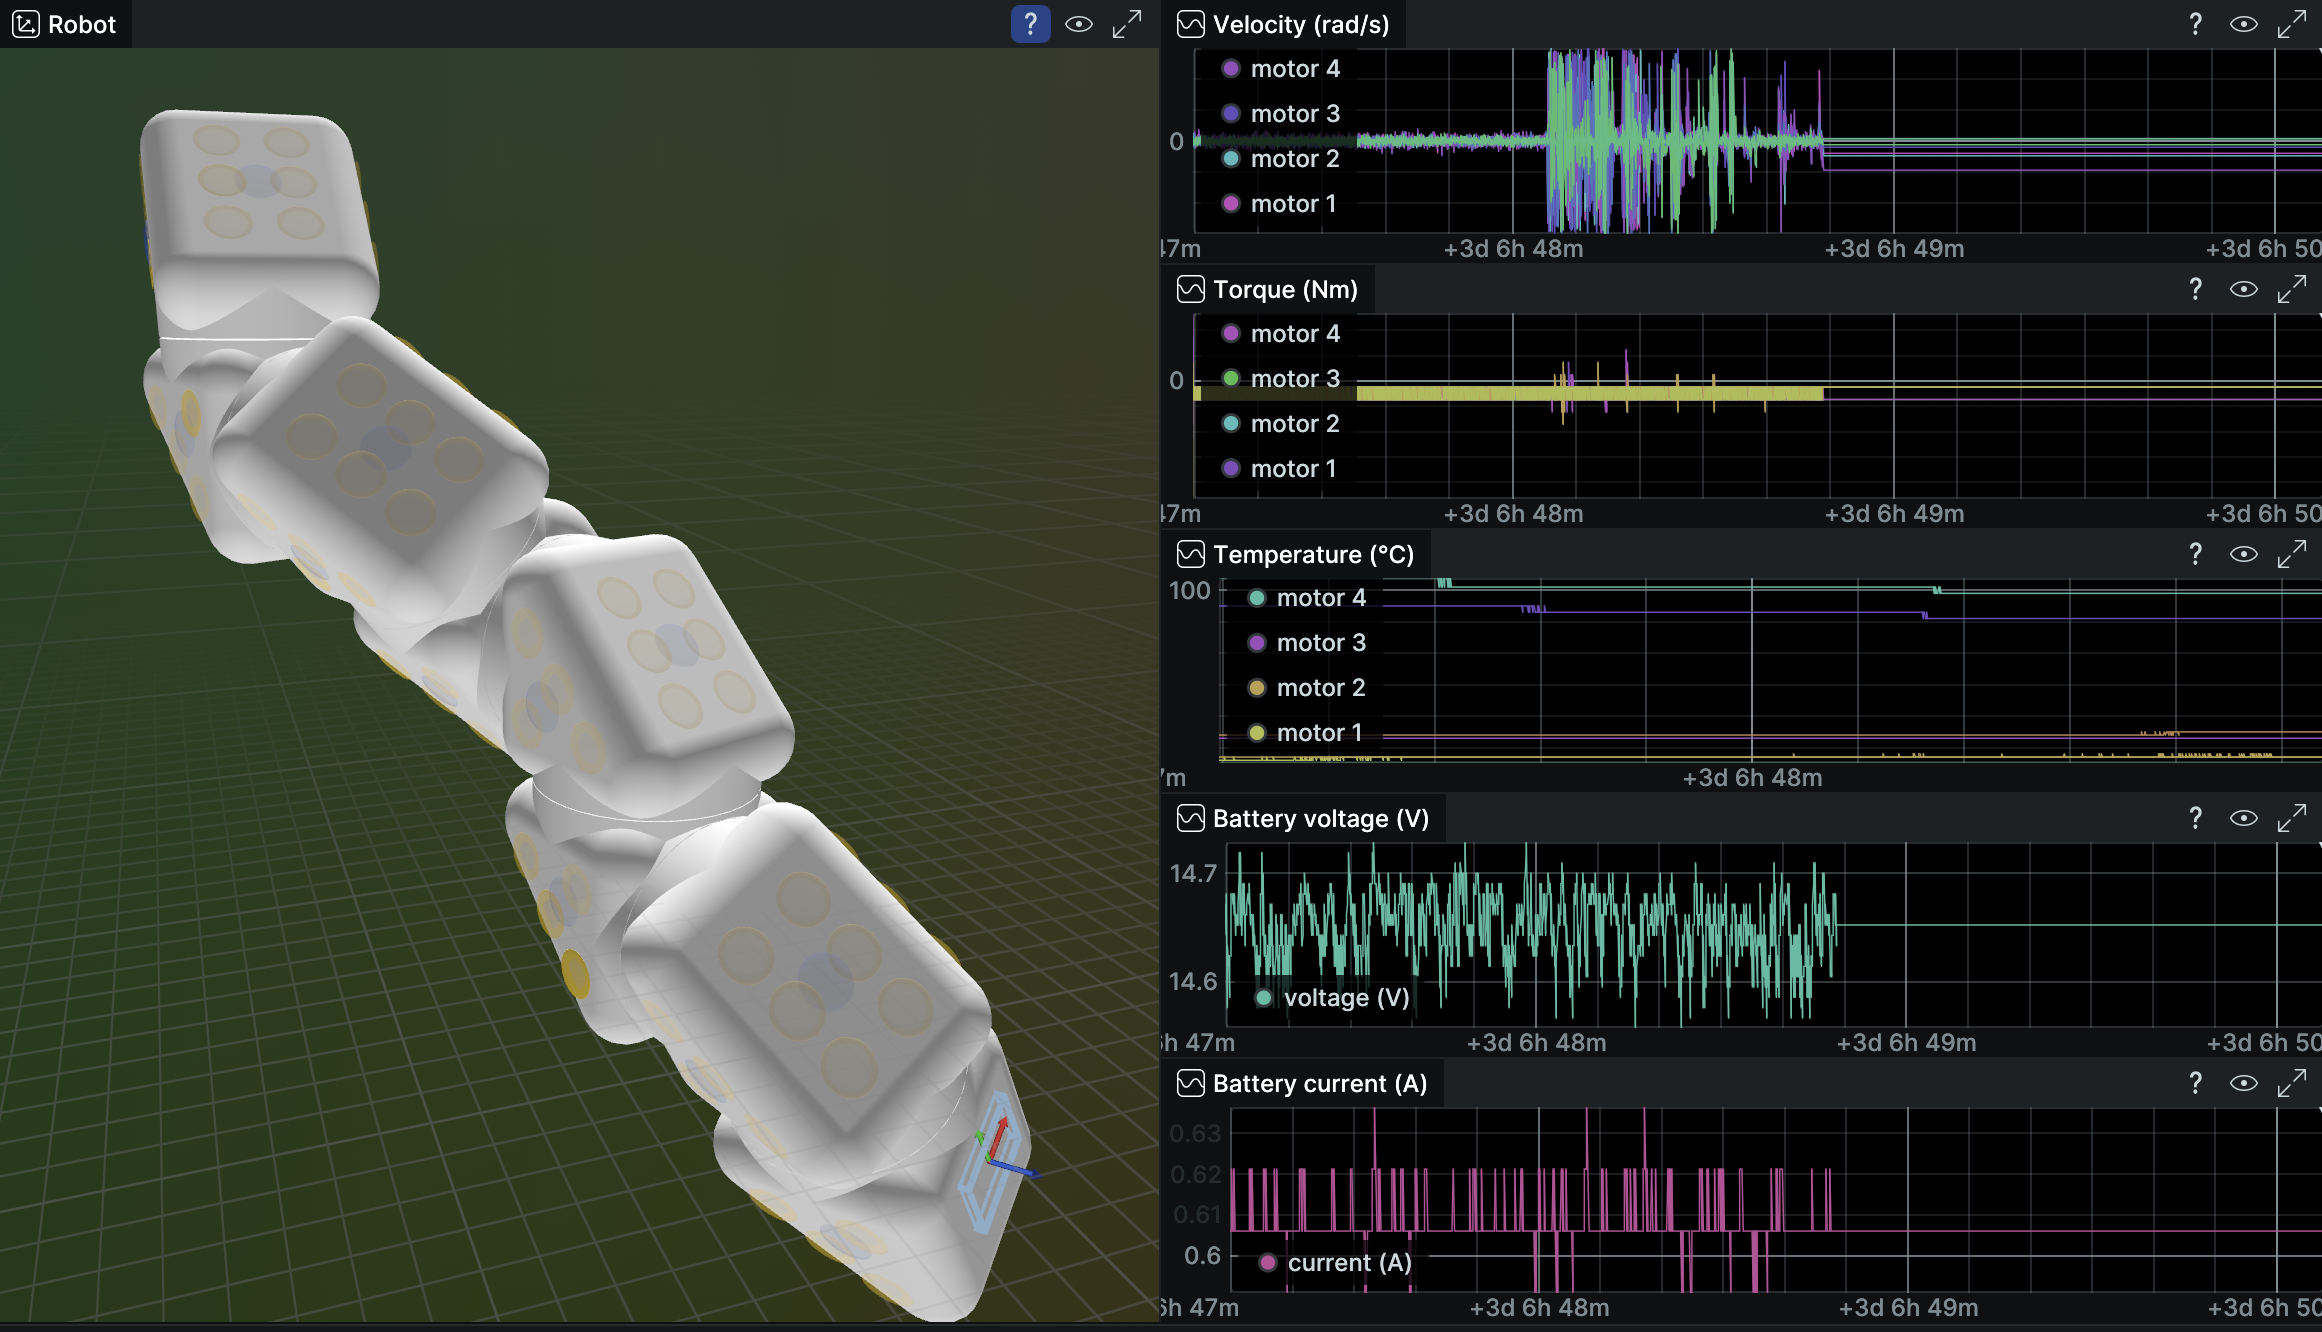
Real-time sensor and motor telemetry
PET is in active development. Multiple versions are in the works: a collectible, a human-sized version for performance, and one that is room-scale for installation. If you are interested in collaborating, please reach out.
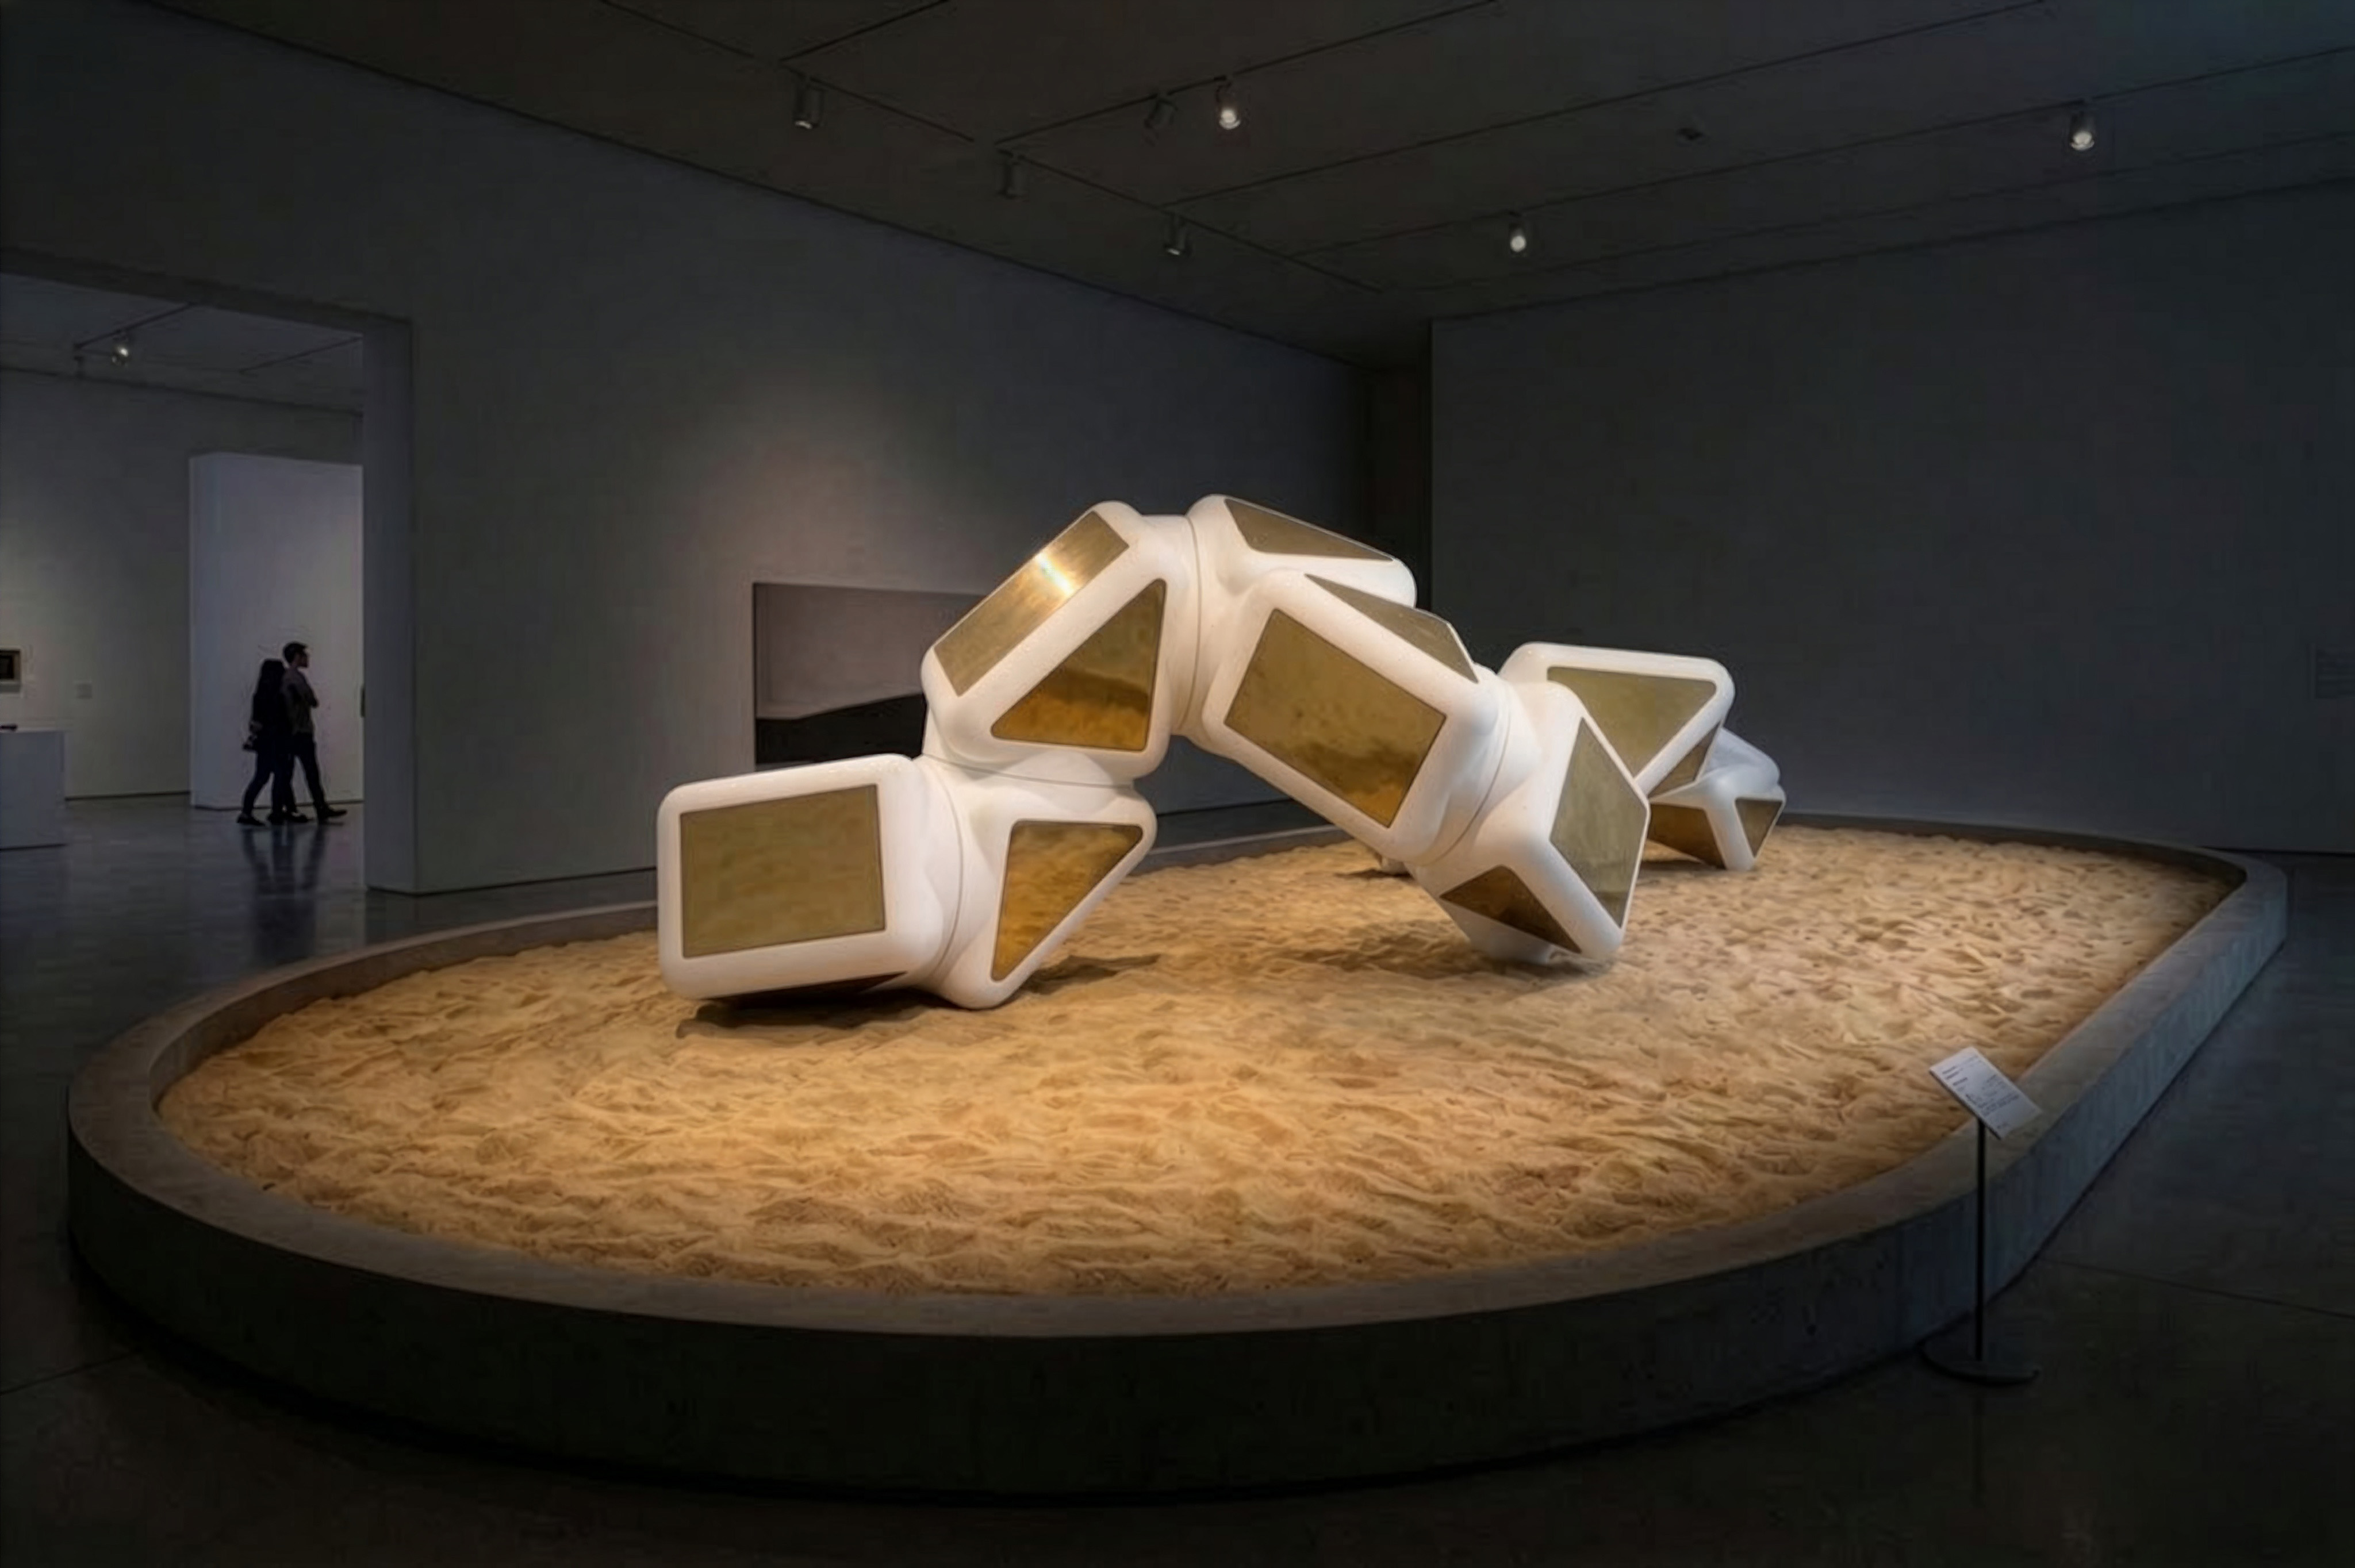
Installation concept